Embodied Intelligent Robot
Humanoid Force-Controlled Arm AR Series Embodied Intelligent Robot
Features
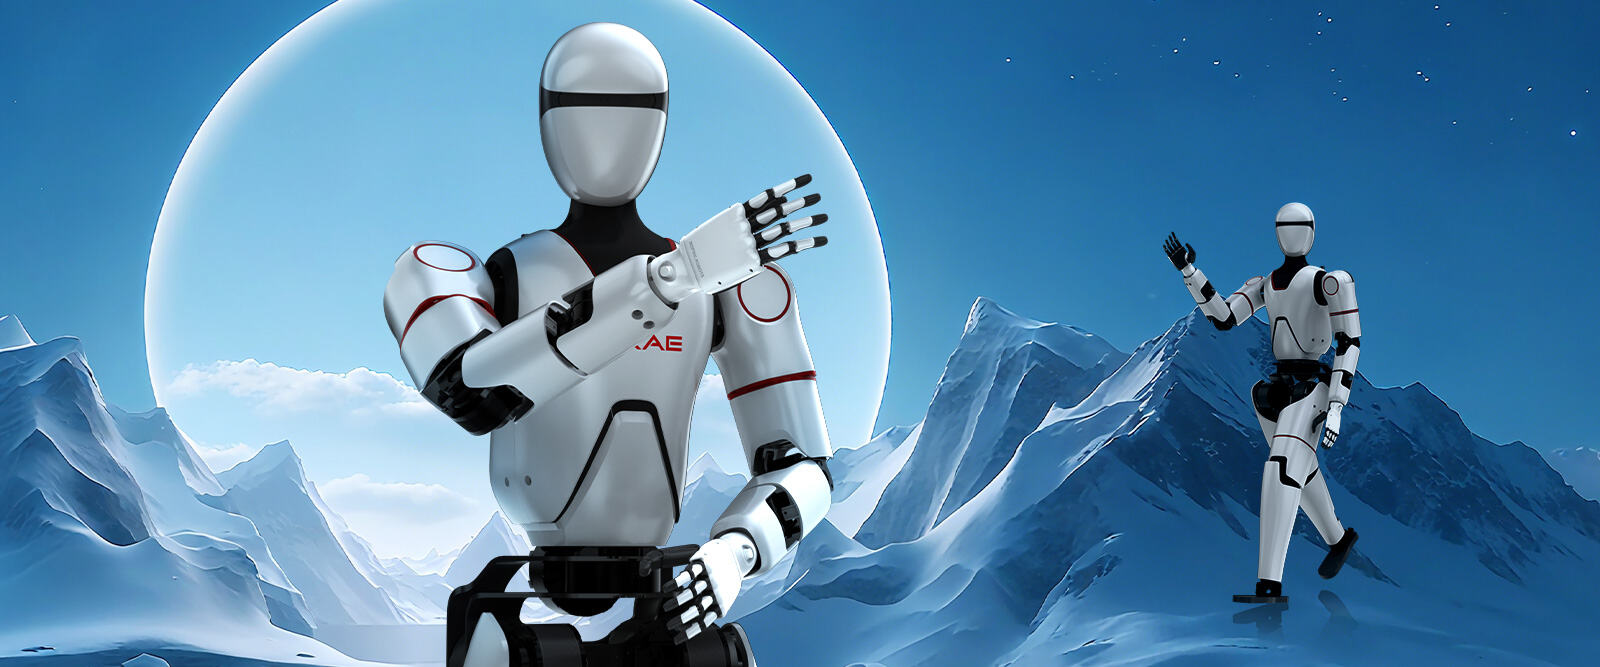
Full-size Humanoid Robot
A life-sized, embodied humanoid robot
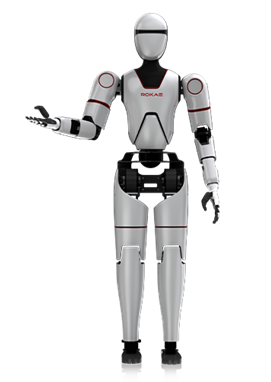
Humanoid Robot Human.X
An advanced, life-sized humanoid platform designed for complex mobility, dynamic balance, and precise manipulation tasks resembling human ones.
Standing Height
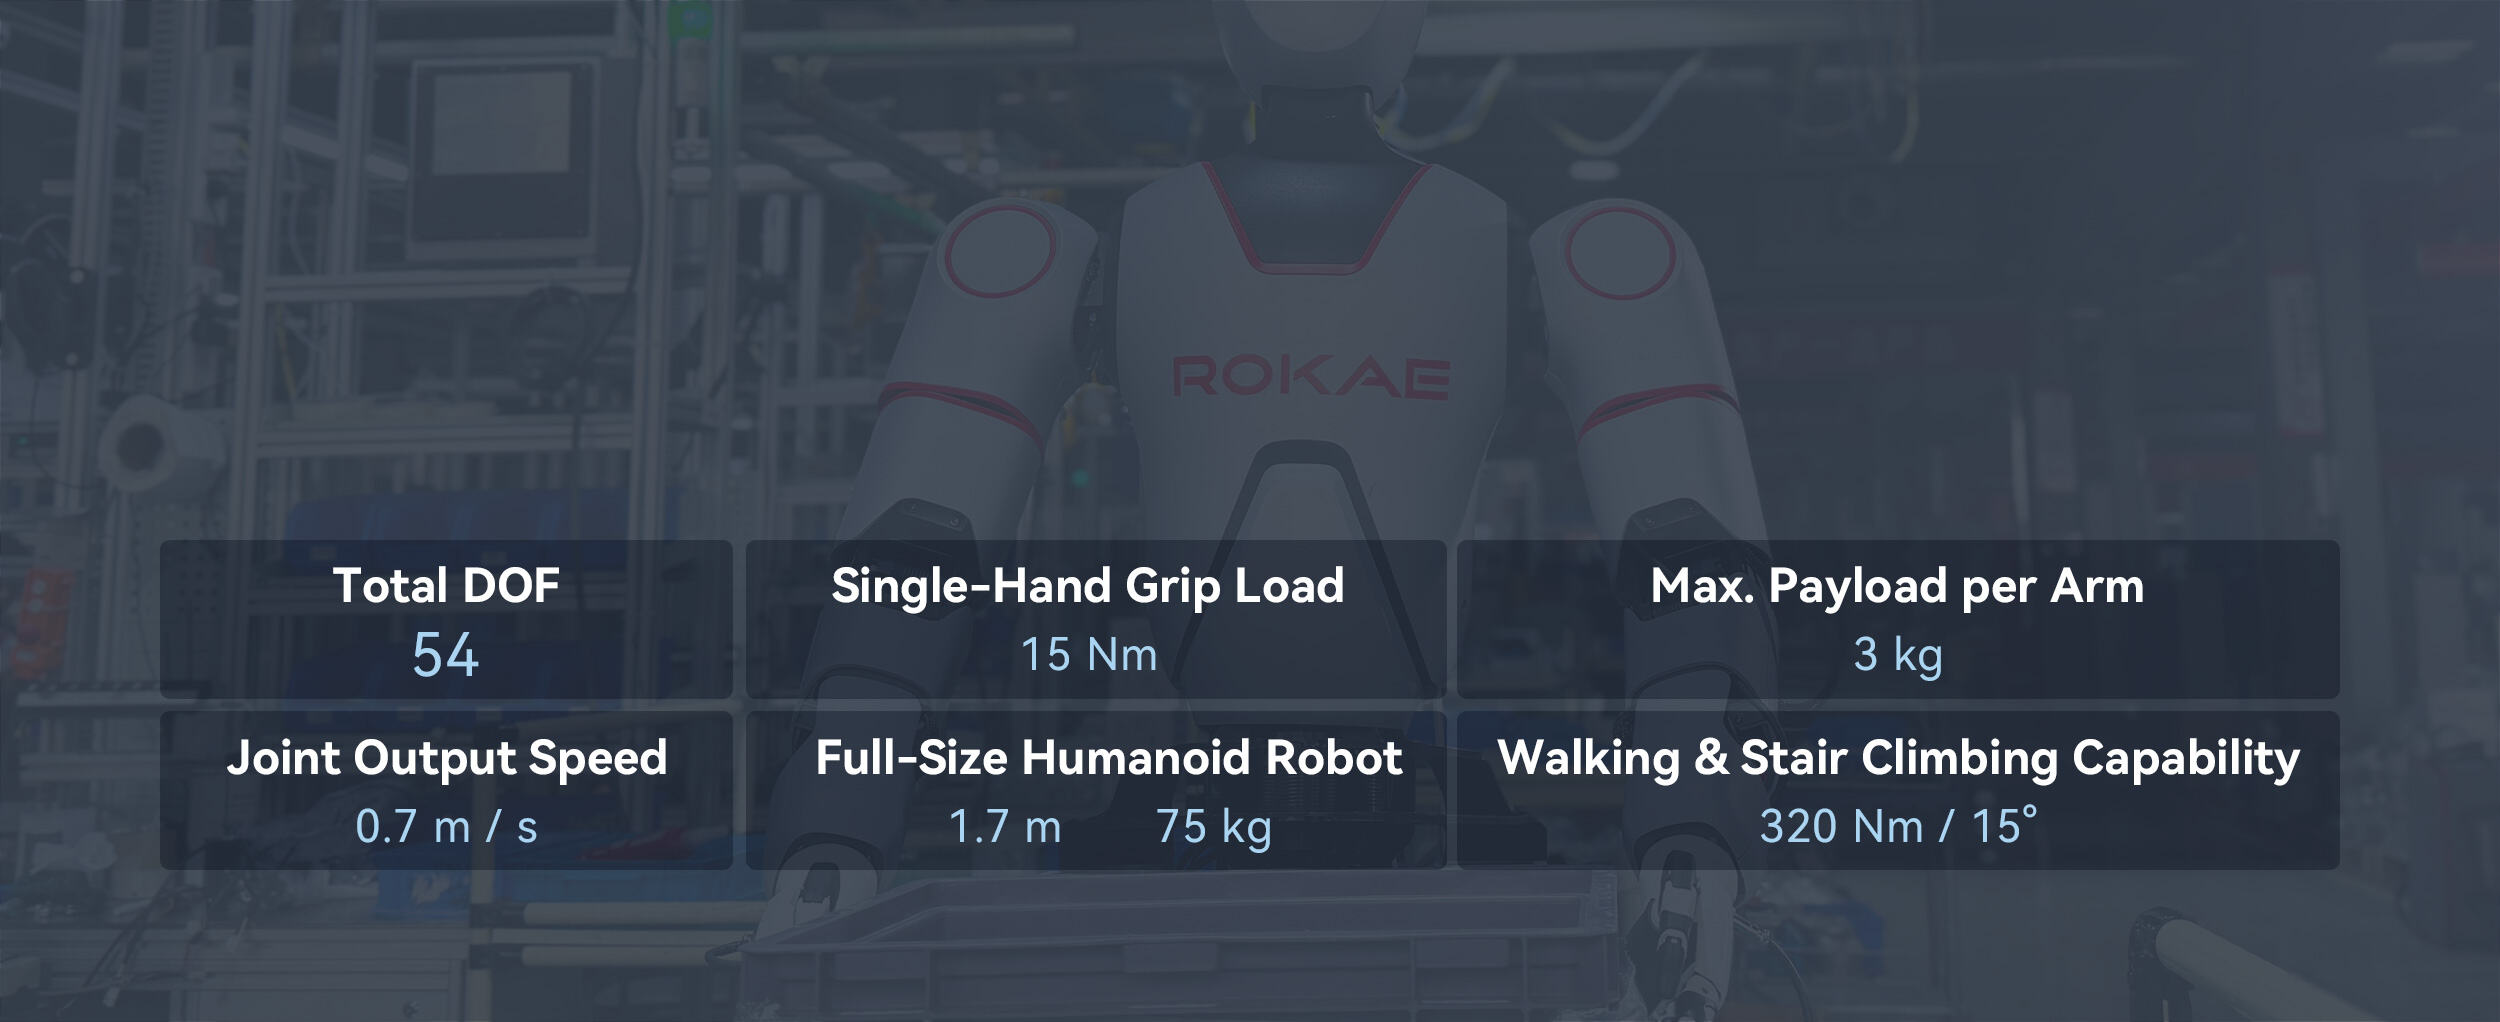
1.7 m
Weight
~75 kg
Payload per Arm
3 kg / per arm
Max. Walking Speed
≥0.5 m/s
Kinematics and mobility
| Arms | 7 DOF |
| Legs | 6 DOF |
| Waist | 2 DOF |
| Neck | 2 DOF |
Locomotion and work environment
Stair Climbing Ability
Slopes ≥15
Payload conditions
The stated 3kg capacity excludes standard or custom end effectors.
Adaptable Road Types
Outdoor cement roads
standard civil building stairs
Profile of a five-fingered anthropomorphic palm
| Degrees of Freedom (for each palm) | 6 DOF | Number of Joints | 12 joints |
| Weight | 540 g | Max. Lateral Rotation of Thumb | Max 65° |
| Max. Grip Force | 15N (Thumb) | 10N (Other fingers) | ||
| Grip Force Resolution | ±0.5N (Stimulation of human hand for precise grasping operations) | ||
Energy efficiency and management integration
Peak torque at the knee joint
≥320 Nm
Safety feedback for fully force-controlled joint
Drive modes
Hybrid control matrix
Supports routines for real-time torque, speed, and position tracking
Sensory architecture
Dual encoder joint module
Provides accurate state space updates for full embedded closed-loop operations
Downloads