Embodied Intelligent Robot
Wheeled Dual-Arm Robot Helios Series Embodied Intelligent Robot
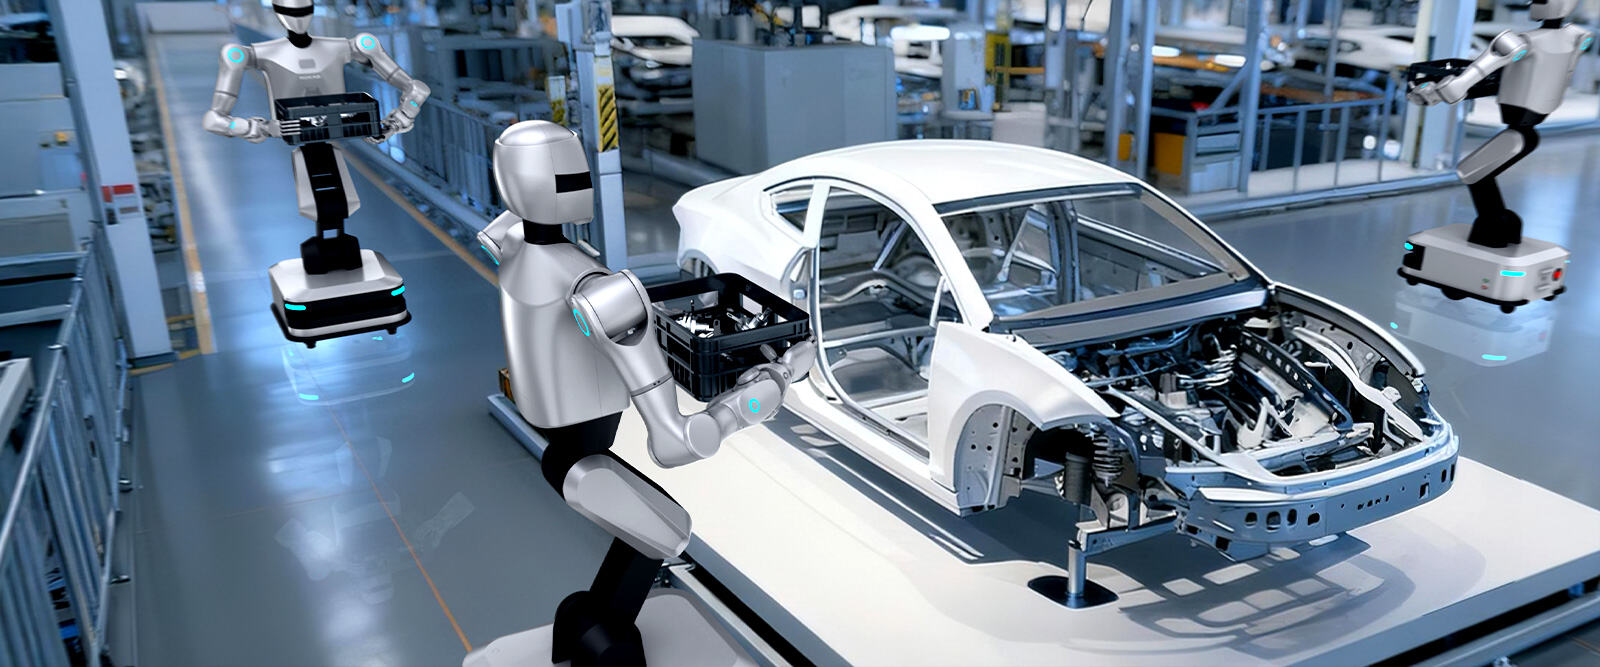
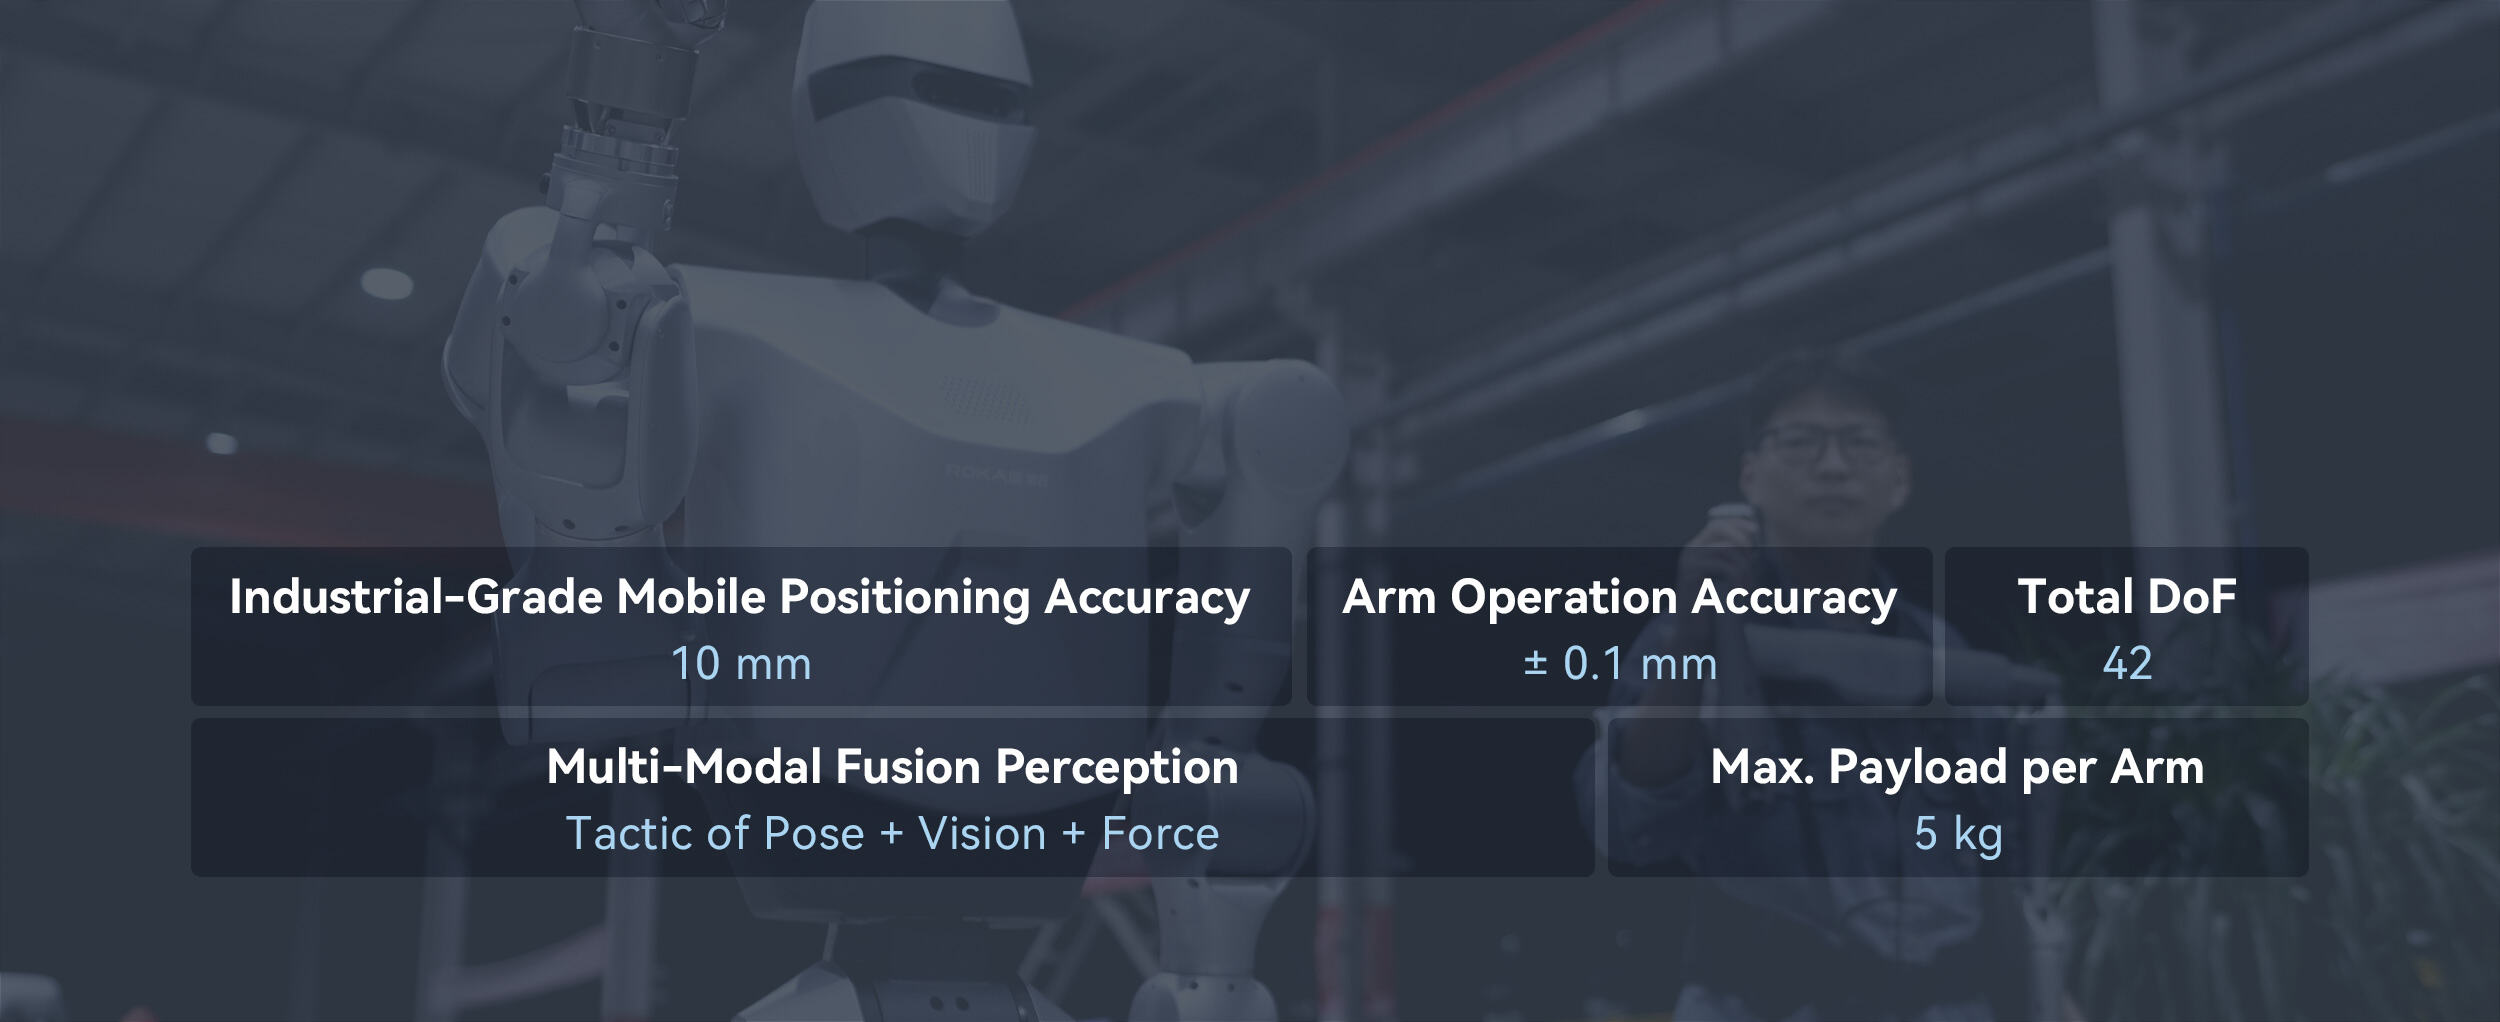
Wheeled Dual-Arm Robot
Embodied artificial intelligence
Helios two-armed wheeled robot
A mobile manipulation platform with two robotic arms, autonomous navigation and advanced perception.
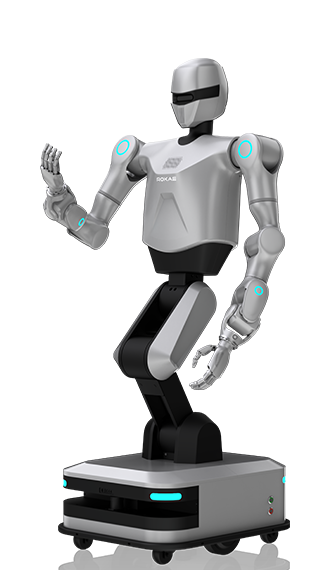
Degrees of Freedom (DOF)
2
Head
7
Arms
4
Torso
6
Fingers (each hand)
2
Mobile Base
Hardware Specifications
Height (extended)
≤600×600×1800 mm
Height (Folded)
≤600×600×1100 mm
Weight
Approx.100 kg
Hand Specifications
Number of Joints
7
Reach
650 mm
Repeatability
±0.1 mm
Payload (per hand)
5 kg
Payload
3 kg
Total number of joints
12
Joint Performance
Lightweight compact force-controlled joints with built-in torque sensors, dual encoders, and EtherCAT communication
Dexterous Hand (Optional)
Degrees of Freedom (DOF)
6
Weight
540 g
Grip Force
Thumb: 15 N; Others: 10 N
Thumb Movement Range
65°
Maximum speed
1.2 m/s
Mobile Base
Drive Mode
Differential Drive
Obstacle Clearance
1.5 cm
Navigation
SLAM navigation algorithm
Battery Performance
Battery capacity
24V 40AH LiFePO4
Operating time
Approx. 5 hours
Charging time
4 hours
Computing Power
Performance superior to 12th Gen Intel Core i7
Sensors
Head Vision
Binocular visual system with structured light, RGB and depth sensor.
Obstacle-Avoidance
3D Camera on Chassis
Interaction
Microphone and speaker, supporting voice playback and quiet-scene conversation
Secondary Development
Communication
Ethernet, WiFi
SDK and interfaces
ROS2 compatible SDK with low-level joint access, sensor access, and high-level motion API.
Working environment
Temperature
0~40°C
Humidity
5%~85%
Requirements
Dust-free, non-corrosive gas, and static-free particles.